
CNC Milling Cutting Tools: Machining Methods and Optimization Guide
A Mentor CNC engineering guide — from entering-angle analysis and chip-thinning mechanics to climb vs conventional milling, ISO material strategies and plunge milling — that extends tool life, efficiency and surface quality.
1. Introduction: Modern Milling Technologies and Industrial Trends

The most flexible and versatile metal-removal method in industrial manufacturing, milling sits at the center of modern production alongside evolving machine and software platforms. Intelligently designed insert geometries, optimized seats and modular exchangeable-head systems deliver high stability regardless of material or cutting conditions. At Mentor CNC, this guide covers the core mechanics of milling, the formulas and the specific machining tips that maximize process reliability.
- Advanced axis kinematics and multi-tasking: 5-axis centers and multi-tasking machines minimize the number of setups needed to complete a part.
- Light and fast milling: On less stable machines, low depth of cut + high feed strategies spread.
- Extended tool lengths: Long overhangs and deep pockets become necessary for complex geometries.
- Modern materials: Light, strong, corrosion-resistant alloys, thin-walled flexible parts and near-net-shape production come to the fore.
2. Method Selection and Entering-Angle (κr) Analysis
The best method depends on the simultaneous analysis of part characteristics, material and machine parameters (stability, power, torque, axis count). The entering angle (κr) between the main edge and the surface is the dominant factor determining force direction, chip thickness and tool life.
| Entering Angle | Type | Characteristics |
|---|---|---|
| 90° | Square-shoulder mill | Focuses force radially; no axial load on the part. Ideal for thin-walled/flexible parts and weak fixtures. Universal for end, shoulder and slot milling. |
| 45° | Face mill | Balanced axial+radial force; softer entry. Minimizes chatter at long overhang, weak spindles and unstable clamping. Chip thinning enables high feed. Reduces edge chipping in brittle materials. |
| 60°–75° | Rough face mill | Much higher ap than 45°; much stronger, more wear-resistant edge than 90°. |
| 10° | High-feed mill | Enormous chip thinning → very high vf. Directs force axially (along the spindle), stabilizing it; eliminates radial deflection in long setups. A problem-solver for pocket plunging and helical hole making. |
| Round insert | Die / heavy roughing | Highest edge strength. Entering angle varies 0–90° with ap; distributes force, protects against thermal shock. First choice for titanium and super alloys. |
3. Milling Theory, Formulas and Chip Thinning
3.1. Core Machining Formulas
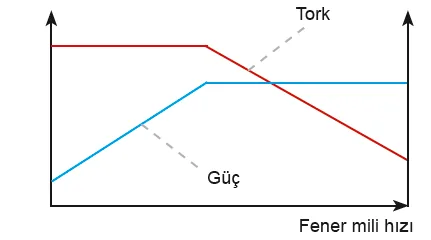
3.2. Chip Thinning and Feed Optimization (hex)
The most critical parameter is maximum chip thickness (hex). Too low → rubbing instead of cutting, excess heat and chatter; too high → instant edge fracture. Feed (fz) is increased geometrically in three cases:
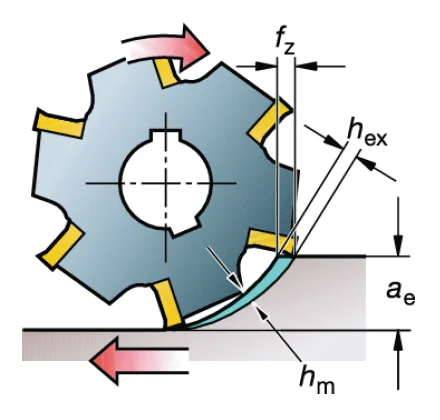
3) Radial Engagement Effect: When ae/Dc < 50%, the edge exits early and the chip thins; to hold the target hex, fz is raised by a modification factor (e.g. at 5% radial engagement, feed 2.3×).

| ae/Dc | Factor | fz for hex = 0.10 | hex = 0.15 | hex = 0.20 |
|---|---|---|---|---|
| 50–100% | 1.00 | 0.10 | 0.15 | 0.20 |
| 25% | 1.16 | 0.12 | 0.17 | 0.23 |
| 20% | 1.25 | 0.13 | 0.19 | 0.25 |
| 15% | 1.40 | 0.14 | 0.21 | 0.28 |
| 10% | 1.66 | 0.17 | 0.25 | 0.33 |
| 5% | 2.30 | 0.23 | 0.34 | 0.46 |
4. Process Dynamics: Chip Formation, Entry and Corner Management
4.1. Climb (Down) vs Conventional (Up) Milling
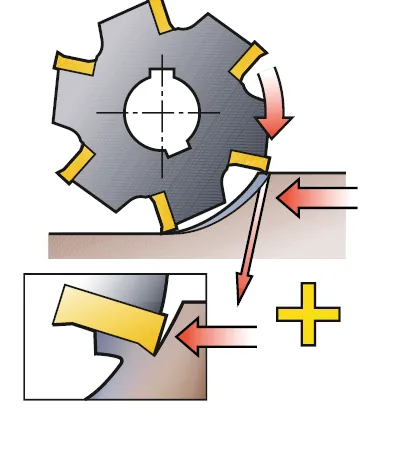
- Climb milling: Rotation = feed direction. The chip starts at max thickness and drops to zero at exit; no rubbing, maximum life. Force presses the part onto the table. The primary choice in every suitable operation. (On old/unstable machines, watch for uncontrolled feed surge from screw backlash.)
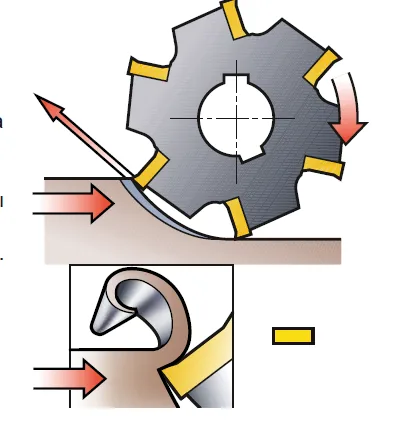
- Conventional milling: Feed opposite to rotation. The chip starts at zero and peaks at exit; the edge rubs on entry → excess heat, chatter, cutting the work-hardened layer, chip welding at exit and sudden edge breakage. Force lifts the part off the table.
4.2. Soft Entry and the “Roll-In” Method
A radial cutting edge contacts the workpiece in three phases: entry into cut, arc of engagement, and exit from cut. For a carbide insert the most sensitive moment is the exit: at the end of the cut the chip is unsupported, tries to bend and puts the edge under tensile stress. The position of the cutter relative to the workpiece sets the load in all three phases.


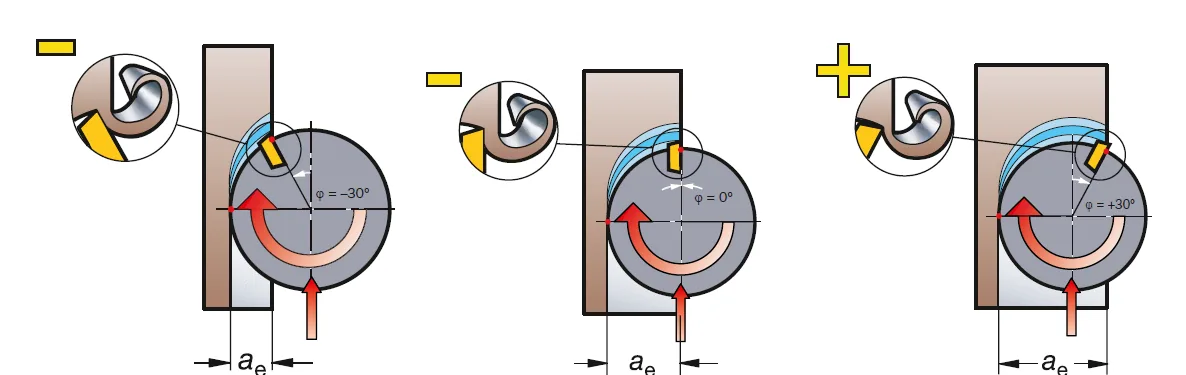

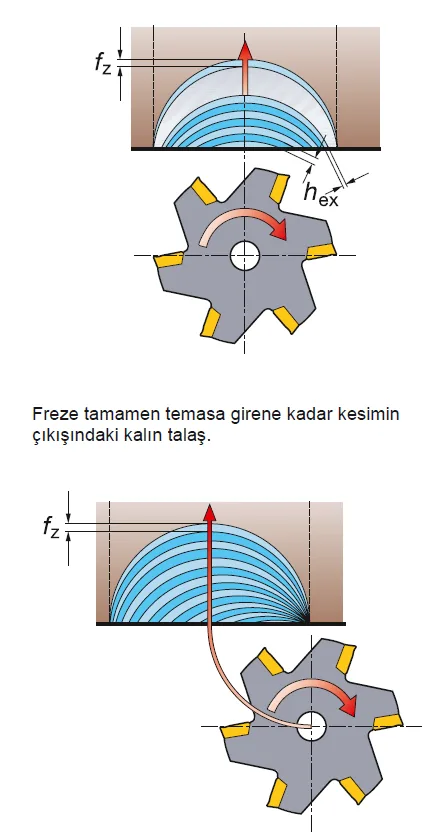
When the cutter enters straight (linear), very thick chips form at exit until full engagement; on hardened steel, titanium and super alloys this creates instant thermal/mechanical shock. Two methods:
- Feed reduction: Reduce the linear-entry feed by 50% until the cutter reaches full engagement.
- Roll-in entry: Program the toolpath to enter along a clockwise arc rather than a straight line; the exit chip thickness always stays at zero, allowing higher starting feed. (Counter-clockwise entries do not solve the thick-chip problem.)
4.3. Inner-Corner Arc Instability and Radius Management
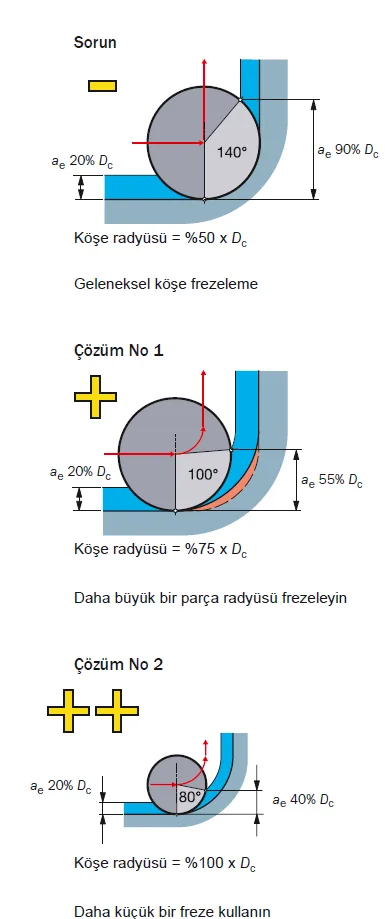
When the tool moves straight into an inner corner, the radial contact arc grows suddenly (e.g. 20% on the straight jumps to 90% in the corner, with the engagement angle reaching 140°); this causes severe chatter, dimensional drift and sudden fracture. Rules:
- Radius relation: In roughing, a toolpath radius equal to 50% of the part corner radius (or a smaller cutter) lowers the contact arc. In finishing, the cutter diameter must not exceed 1.5× the part inner-corner radius (Dc ≤ 1.5 × part radius).
- Corner feed reduction: Use full feed on the straight (fn1); on entering the corner radius (fn2), reduce feed by at least 50% to round the contour.
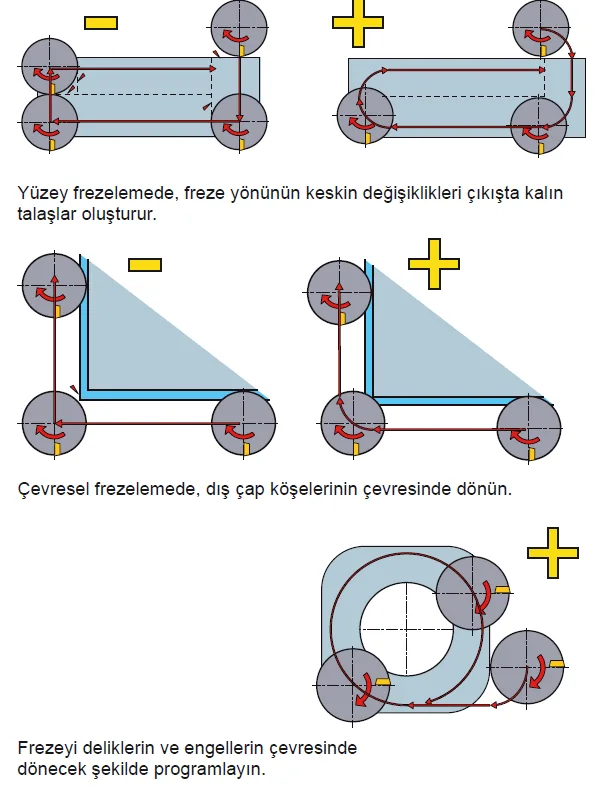
Keep the cutter in continuous contact. Sharp changes of direction in the toolpath behave like a straight entry: a thick exit chip and a sudden load. Instead of stopping and turning in a corner, roll around it on an arc, choose a width of cut of about 70% of Dc so the corner is fully covered, and program around holes and obstacles with arcs as well.

5. Milling Strategies by Material Group (ISO P, M, K, N, S, H)
5.1. Steel Milling (ISO P)
- Soft steels: Main issue is smearing (BUE) and exit burrs. Solution: sharp, positive-rake light (L) geometries and thin PVD-coated grades that resist adhesion.
- Hard steels: Exit position matters — place the cutter off-center (left) to avoid thick chips at exit. Thick MTCVD-coated hard roughing geometries (H/M). Rough milling is done dry to avoid thermal cracks. On small diameters (Dc ≤ 32 mm), tough PVD with reinforced microstructure is first choice.
5.2. Stainless Steel Milling (ISO M)
Dominant damage: thermal shock cracks, work-hardening notch wear and high adhesion. Rough milling must be dry; use very positive sharp micro-geometry; spread the notch with round inserts/small entering angles. In finishing, since temperature drops, coolant/mist can be integrated to prevent adhesion. To tear the hardened layer for a clean cut, do not keep fz too low. On cast stainless, thick CVD tough grades play a complementary role.
5.3. Cast Iron Milling (ISO K)
Main criteria: abrasive flank wear and thermal cracks; edge chipping at exit corners. In roughing use dry cutting + thick CVD wear-resistant rough geometries; reduce feed slightly or use positive light geometry to reduce edge break-out. In stable continuous face milling, silicon-nitride ceramics push Vc > 800 m/min (ceramic must run dry). In finishing, CBN running dry at high speed produces mirror surfaces. CGI: sharp positive geometry + tough PVD to prevent burrs; ADI: abrasive/hard, so high-friction-resistance hard grades.
5.4. Heat-Resistant Super Alloys (HRSA) and Titanium (ISO S)
Poor thermal conductivity limits cutting speed; the main damage is notch wear and edge chipping.
- Common rules: Use round inserts or < 45° entering angles to spread the notch; positive micro-geometry with excellent edge honing to prevent chip welding. With carbide, 70 bar high-pressure coolant through the spindle is a mandatory requirement.
- Ceramic milling (roughing): On nickel-based super alloys (e.g. Inconel 718), silicon-nitride ceramics run 20–30× the speed of carbide (Vc = 700–1000 m/min). Due to brittleness keep fz shallow (~0.1 mm/tooth), dry mandatory. Ceramics must never be used near-net-shape finishing or on titanium.
5.5. Hardened Steels (ISO H)
On 45–65 HRC die steels the main criteria are abrasive flank wear and edge break-out. Use very precisely ground sharp positive geometry; run dry. For rough/semi-rough pocketing use low-force trochoidal milling or high-feed shallow face milling (“light and fast”). In finishing, ultra-hard smooth PVD end mills or CBN for mirror quality.
5.6. Aluminum and Non-Ferrous Materials (ISO N)
ISO N covers not only aluminum but also magnesium, copper and zinc based alloys. In aluminum the key machinability factor is the silicon (Si) content: hypo-eutectic alloys below about 13% Si are the most common type and cut easily; as Si rises the material becomes abrasive. Tool life is not set by flank wear as in steel but by built-up edge (BUE) and burr formation. That is why edge wear is a poor life criterion here; burrs and surface finish on the part are what end the tool’s life.
- Sharp, positive geometry: polished rake faces and sharp edges reduce adhesion. Below roughly 8% Si an uncoated fine-grain carbide is sufficient; above 8% Si PCD (diamond) inserts usually give better tool life and cost per part.
- Coolant is mandatory here: while most milling roughing is run dry, aluminum is always milled with coolant to prevent adhesion and protect the surface. Sand inclusions in cast aluminum can be abrasive.
- High cutting speed is free; the rpm limit is not: raising speed generally improves performance without shortening tool life. The limit is not the machine but the maximum rpm rated for the cutter body; never exceed the speed marked on the tool.
- Chip thickness: aim for hex of 0.10–0.20 mm; too low a feed smears instead of cutting and produces burrs.
- Machine side: at very high table feeds, enable the control’s look-ahead function to avoid dimensional errors in corners. Good chip evacuation prevents chip scratches on the soft surface.
6. Process Safety: Thermal Shocks, Tool Maintenance and Torque
6.1. Cyclic Thermal Stress and the Case for Dry Cutting
Milling is an interrupted operation: each tooth heats rapidly on entry (~1000°C) and cools suddenly in the air phase. This fluctuation creates thermal shock cracks (comb cracks) in the carbide. In roughing, spraying external coolant increases the hot-cold swing, growing the cracks and breaking the edge early. For this reason modern rough milling must be run fully dry.
6.2. Seat Maintenance and Torque Precision
At every change, inspect the seat for burrs/deformation; clean micro-dust and dried oil with compressed air; replace worn screws/washers. To prevent runout (TIR), disassemble bolt connections at least once a year and lubricate with high-temperature paste.
- Excessive torque: Permanent damage to screw/washer; micro-cracks the brittle insert and it shatters at first load.
- Insufficient torque: Insert/cartridge micro-moves → severe chatter, poor surface, fast fracture.
7. Mentor CNC Machining Tips and Special Methods
7.1. Milling Thin, Flexible Walls
- H/T < 15:1: With non-overlapping passes, machine face A fully, then face B; leave a finishing allowance.
- H/T < 30:1: Waterline: the tool circles at a constant Z level in stepped passes. Staircase support: passes on opposite walls overlap axially (zigzag), keeping material behind the cut as a support leg; first pass depth is half (ap/2), leaving 0.2–1.0 mm per flank for finishing.
- H/T > 30:1: The “Christmas Tree” method: while machining the thin top section, the uncut thick sections below give support; the tool descends in a stepped spiral, fully blocking deflection.
7.2. Hole Making by Helical Interpolation
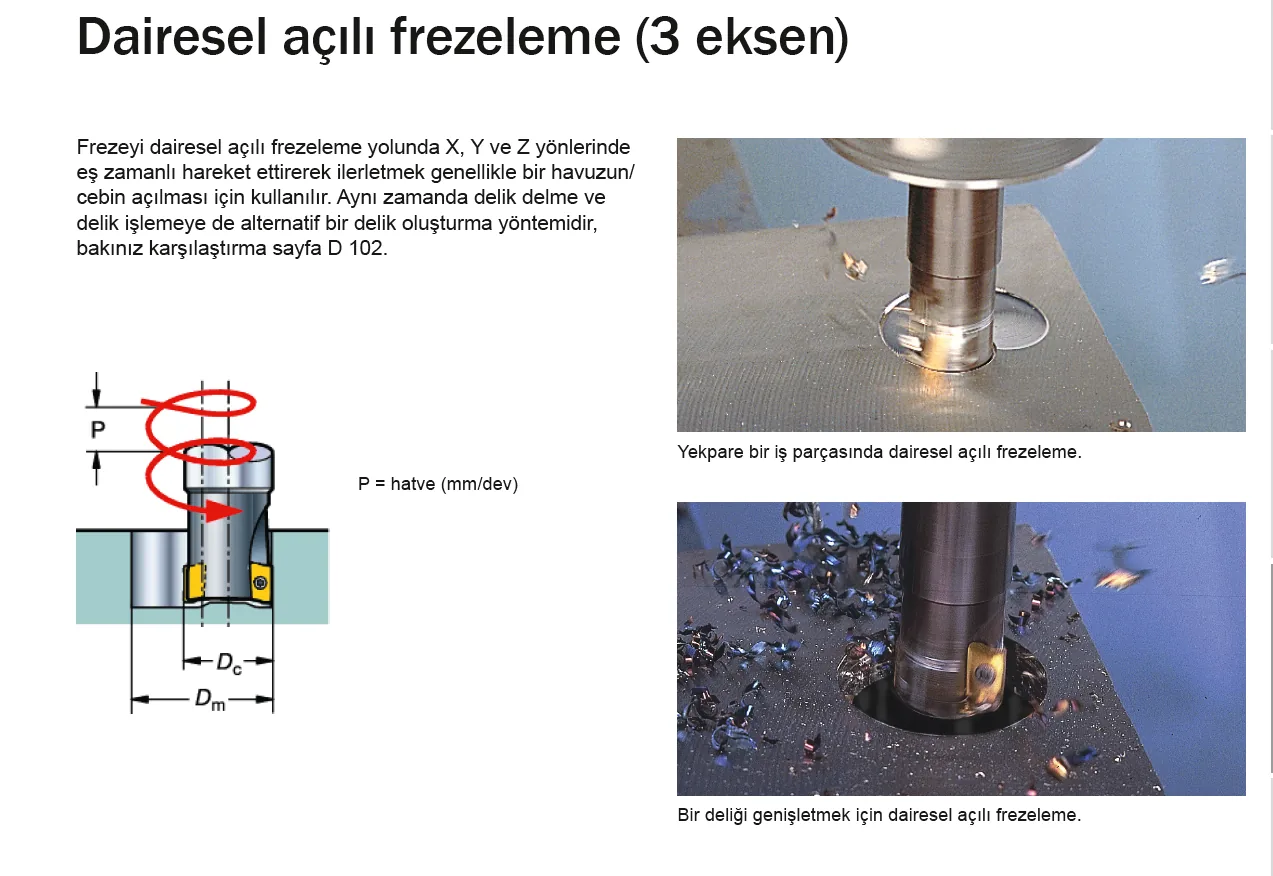
In drill-free circular hole making with synchronized X-Y-Z motion, the relation between cutter diameter (Dc) and hole diameter (Dm) must be perfect; counter-clockwise helical paths always maintain stable climb milling.
When to mill a hole instead of drilling it? Drilling is the fastest way to make a hole; helical (circular ramp) milling is slower but is the right choice when:
- The hole is large and machine power is limited.
- The batch is small: above 25 mm diameter, milling is usually economical up to roughly 500 holes.
- There are many different hole sizes on one part, or there is no magazine space for every drill size; one cutter makes them all.
- A flat-bottomed blind hole is required.
- Thin-walled, non-rigid parts and interrupted cuts.
- Materials with poor chip breaking or difficult chip evacuation; machines without coolant.
- Non-round holes, pockets and cavities.
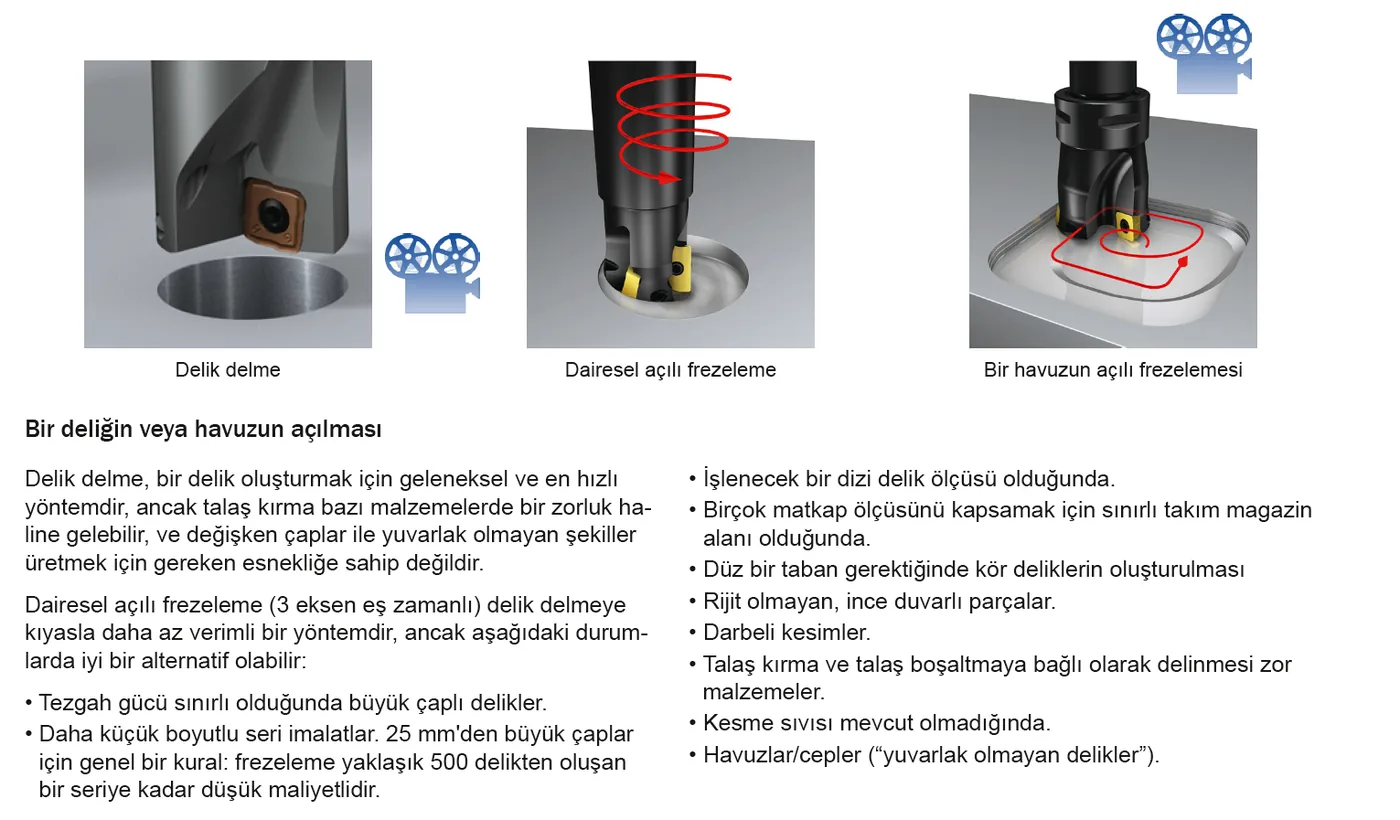
Three critical settings in helical hole milling. Three points cause trouble when set wrongly: cutter diameter, pitch per revolution and feed.

- Cutter diameter: with cutters that do not cut to center, the insert must pass through the hole center line. If the cutter is too small a core is left in the middle (in a through hole the falling core must be supported; in a blind hole it is not acceptable). If the cutter is too large, a pip remains at the center and hits the cutter bottom. That is why the lower and upper diameter limits above exist.
- Pitch (P, mm/rev): the depth descended per revolution can never exceed the cutter’s maximum depth of cut ap; it is chosen from hole diameter, cutter diameter and ramp angle.
- Feed correction: the feed is calculated from hex and that value is the peripheral feed at the cutting edge (vfm). Most controls, however, want the tool center feed (vf). Inside a hole the center travels a smaller circle, so the programmed F value must be reduced:
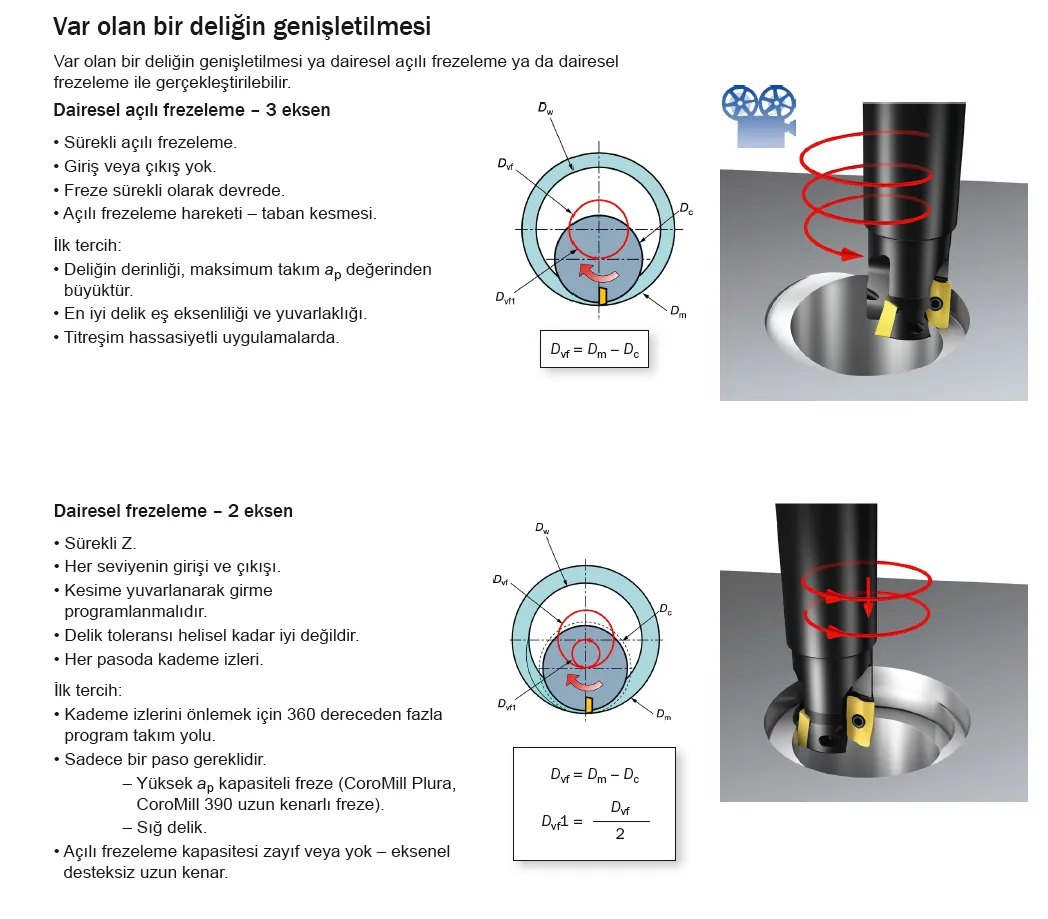
Enlarging an existing hole: helical or circular? A helical path (3 axes simultaneously) is continuous: no entry or exit, the cutter stays in the cut, and roundness and concentricity are best. It is the first choice when the hole depth exceeds the cutter’s maximum ap and in vibration-sensitive jobs. A circular path (2 axes, full turns at constant Z) suits shallow holes finished in one pass with long-edge cutters; program a roll-in at every level and slightly more than 360° so no step mark is left. Hole tolerance is not as good as with helical milling.
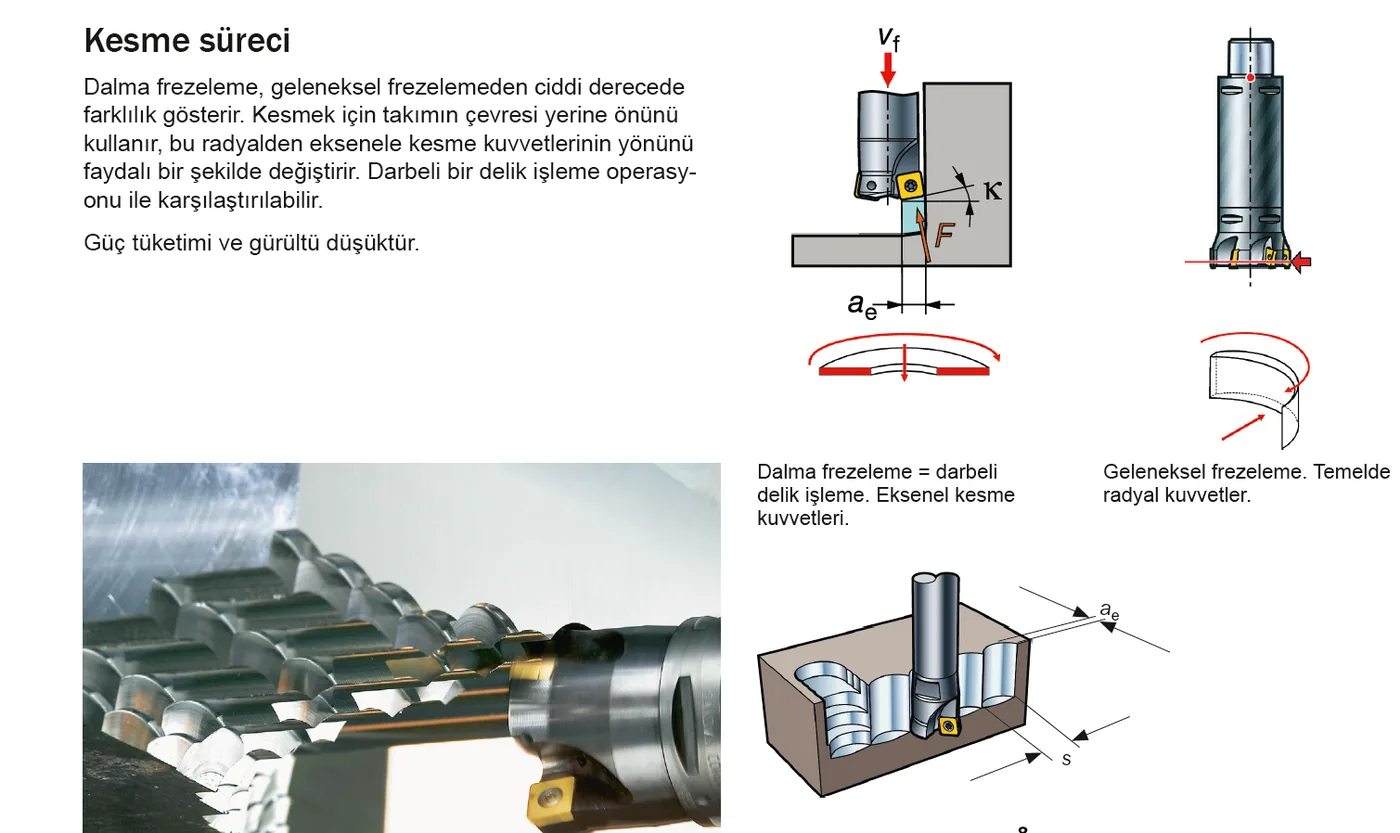
7.3. Plunge Milling
In extremely deep pockets where L/Dc > 4, radial edge milling becomes impossible due to deflection; plunge milling — which converts force from radial to axial (along the bearings) — is the safest alternative. The tool plunges axially, removes the chip and retracts. To prevent the back faces rubbing the wall on retraction, use a “hook program”: at the deepest point, before retracting, move radially 1 mm away from the wall, then retract and shift to the next plunge (step s = 0.75 × Dc). This circular hook motion fully secures the process.
When to plunge? Plunge milling cuts with the face of the cutter rather than its periphery, so the cutting force is axial (along the spindle) instead of radial. It resembles an interrupted boring operation: power consumption and noise are low. It is the alternative when side milling fails because of vibration:
- Tool overhang longer than 4 × Dc.
- Machine, fixture or workpiece lacks rigidity.
- Semi-roughing of corners (removing the remaining stock).
- Difficult materials such as titanium; insufficient machine power or torque.
Application tips
- Start the cut at the bottom and work upward. A horizontal machine, coolant or compressed air help chip evacuation.
- Keep the feed per tooth (fz) lower than in conventional milling; more than one tooth must be in the cut at a time, so prefer a close-pitch cutter.
- Side step s = 0.75 × Dc. Reduce the plunge depth gradually with each step to minimize vibration.
- Use the hook motion on retraction so chips are not recut. Do not plunge mill with a drilling cycle (G81/G83 type): recutting during the rapid retract causes vibration.
- In pockets and cavities, first drill the largest possible starting hole (about 1.5 × Dc) and reduce the feed on the first two plunge steps; avoid full-width slotting.
- In deep, narrow slots a drill plunges more effectively than a cutter in terms of chip evacuation and step ratio (up to about Dc = 35 mm).
- Always leave an even, continuous stock for the following finishing pass.
7.4. Linear Ramping and Step-Down Slot Milling
The most common way to enter a closed slot, pocket or cavity without a drill is linear ramping: the cutter descends in Z while feeding in X or Y at the same time (2-axis simultaneous). What the operator needs to know: three cuts happen at once during the ramp; the leading insert cuts both peripherally and on the floor, the trailing insert cuts on the floor. Forces are both radial and axial, and because it is full-width slotting (ae = Dc) the cutter sees extra radial load and long chips.
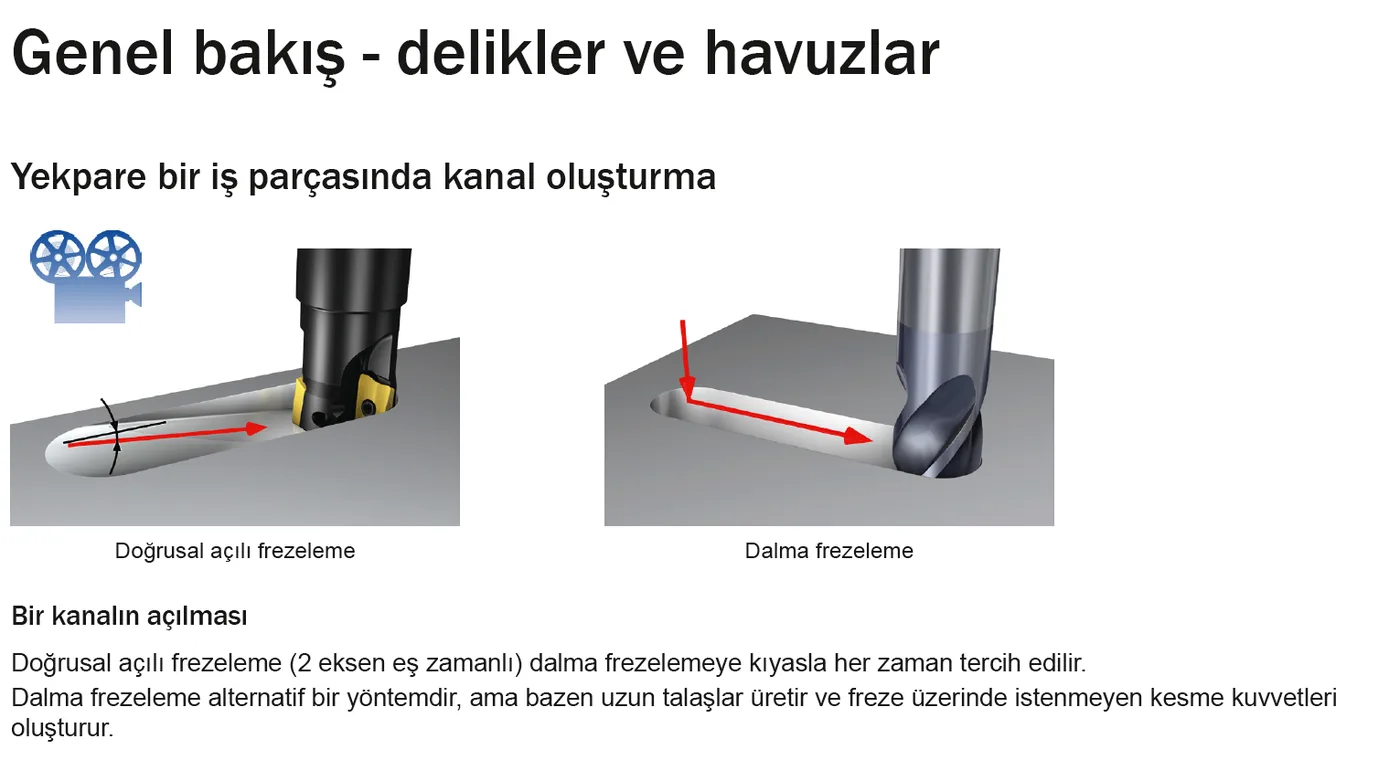
- Reduce the feed to about 75% of normal during the ramp.
- Do not raise the feed the moment the ramp ends: continue at the reduced feed until the trailing insert leaves the cut (about one cutter diameter of travel), then switch to the slotting feed.
- Use coolant or compressed air for chip evacuation. A small insert corner radius reduces the contact area.
- The maximum ramp angle depends on the cutter: the larger the insert radius and cutter diameter, the smaller the permitted angle. Take the value from the tool manufacturer’s catalog; do not guess.
- In a deep slot, ramping in both directions (back and forth, “staged”) raises productivity noticeably compared with one-way ramping. Before reversing, leave a short distance at the end of the path so the center of the cutter body does not strike the floor.

Circular ramping always first. If the machine and program allow it, prefer circular (helical) ramping to linear ramping: radial engagement is lower, pure climb milling is maintained and chips evacuate better (see 7.2).
Step-down (drill-like) slot milling. Plunging an end mill like a drill to open a slot is an alternative to ramping, but it demands high power, produces long chips and loads the cutter with unwanted forces. Use it only when the machine’s ramping capability is weak or for short closed slots. Plunge depth is limited by flute length and chip evacuation; deeper slots need a peck cycle. While plunging, use about 50% of the milling feed. With cutters that do not cut to center (insert seat not reaching the axis) the plunge depth is very limited; use a coarse-pitch cutter for chip space.
7.5. Two Strategies for Pocketing
There are two basic ways to clear a closed pocket; machine rigidity and pocket shape decide which one.
1) Circular ramping with small ap: “light and fast”. Shallow passes and high feed with a small-entering-angle (high-feed) or round-insert cutter. It is the first choice on less rigid machines (ISO/BT 40 class) and for cavities with profiled floors (mold work). Caution: do not cut at full height straight against a 90° wall; the advantage of the small entering angle is lost and the depth of cut suddenly increases.
- Cutter diameter no more than 1.5 × the part corner radius.
- Ramp down to depth on a counter-clockwise circular path; roll into every pass.
- Radial engagement ae no more than 70% × Dc; with round inserts axial depth no more than 25% × iC (insert diameter).
- Toolpath radius in corners = Dc; reduce the feed while turning the corner (see 4.3).

2) Circular milling with large ap: drill first. Drill a starting hole, then open it up on a circular path with a long-edge end mill. This is the typical method for deep pockets such as titanium aerospace frames. The main risk is chip recutting and chip jamming:
- A horizontal-spindle machine (ISO 50 class) is preferred; use high-pressure through-tool coolant or compressed air.
- Cutter diameter no more than 75% of the starting hole; keep the axial depth large (ap up to 2 × Dc).
- Enter the hole on a circular path; radial engagement ae no more than 30% × Dc.
- Program the largest possible radius in corners. Finish roughing with the largest cutter and take the corners with a separate rest-milling pass (see 7.7); the corner cutter diameter should not exceed 1.5 × the corner radius.
7.6. Trochoidal Milling
Trochoidal milling is a slot and pocket method in which the cutter removes material in spiral “slices” along a circular path that keeps advancing. It was developed for roughing and semi-roughing difficult materials such as hardened steel (ISO H) and heat-resistant alloys (ISO S); today it is used in any slotting job with vibration problems. Its logic rests on one thing: a very small radial engagement (ae) combined with a large axial depth (ap) and high cutting speed.
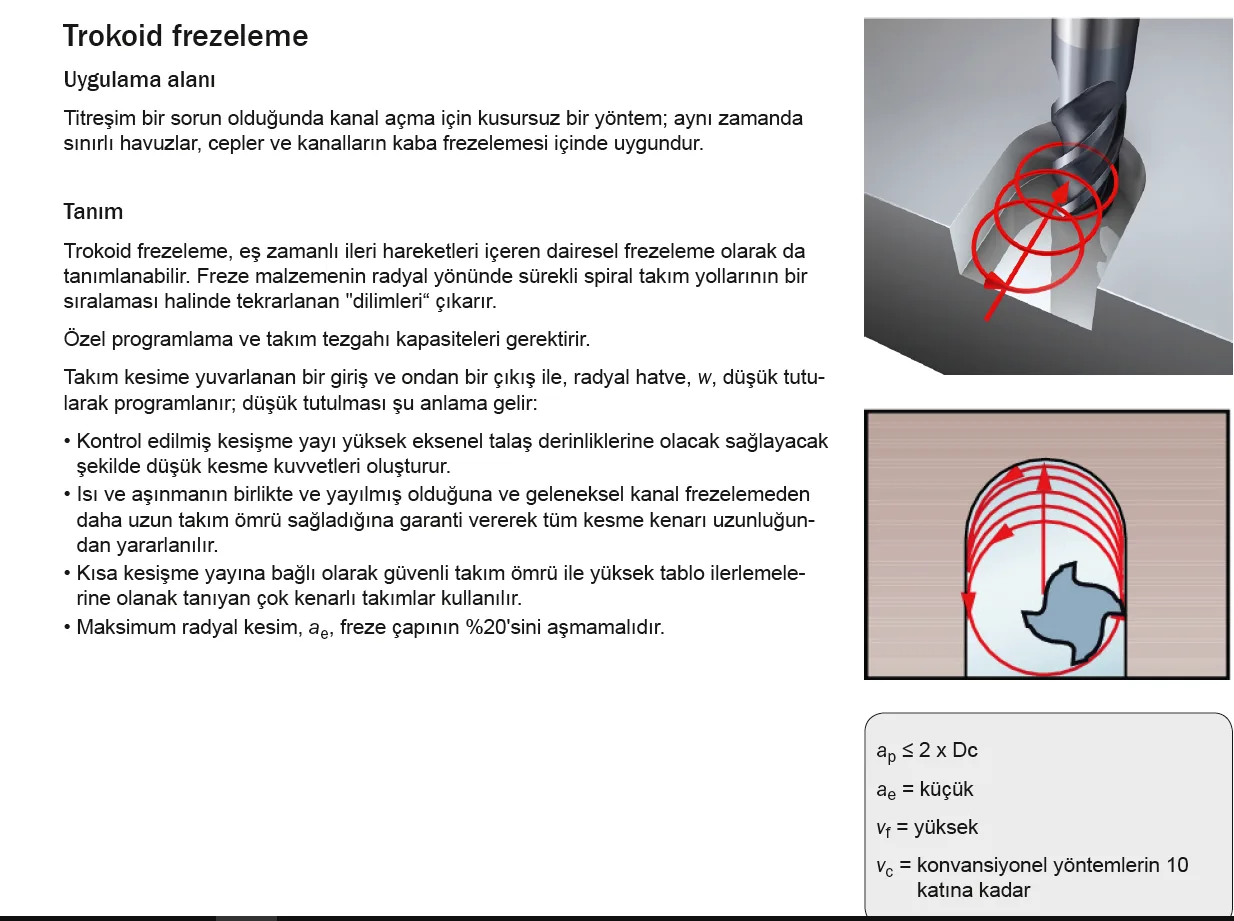
- Small ae → low radial force; deep ap becomes possible even on setups with limited rigidity.
- Only one tooth in the cut at any moment → vibration tendency is minimized.
- Short arc of engagement → less heat in the cutting zone; cutting speed can be several times that of conventional slotting.
- Thin chip thickness (hex) but high fz; wear spreads over the full edge length and tool life increases.
- Multi-flute cutters can be used; a smaller cutter safely opens a wider slot.


Feed correction: as in helical hole milling, the calculated feed is the peripheral feed (vfm = n × fz × zc). The value to program for the tool center is vf = (Dvf / Dm) × vfm, where Dm is the slot width and Dvf = Dm − Dc.
Wide slots (slot width > 2 × Dc): a four-step path is more productive than a continuous spiral: (1) roll into the cut with a programmed radius of about 0.5 × Dc; (2) feed a linear (G1) pass at ae ≈ 0.1 × Dc; (3) roll out with the same radius; (4) rapid to the next start position and repeat.
7.7. Rest Milling: Removing the Stock Left in Corners
When a pocket is roughed with a large cutter, material inevitably remains in the corners. Leaving it to the finishing cutter means vibration and edge breakage, because the arc of engagement jumps in the corner (see 4.3). Rest milling is the technique of semi-roughing the corner with a small cutter in many passes, each with a low radial engagement. The difference from trochoidal milling: the radial engagement starts at zero when entering the corner, peaks in the middle and returns to zero, so no roll-in or roll-out is needed.

- Cutter diameter no more than 1.75 × the finished corner radius.
- Radial step w ≈ 10% × Dc; ap up to 2 × Dc; starting fz ≈ 0.1 mm/tooth; cutting speed can be 3–6 times the normal recommendation.
- As the corner radius gets smaller, the path traced by the tool center shrinks too; the center feed must be reduced with every pass. Otherwise the feed per tooth rises and the process becomes unstable. A machine with good corner feed control is essential.
- The number of passes depends on the corner angle; for corners sharper than 60°, plunge milling may be the better solution (see 7.3).
8. Milling Problems and Solutions
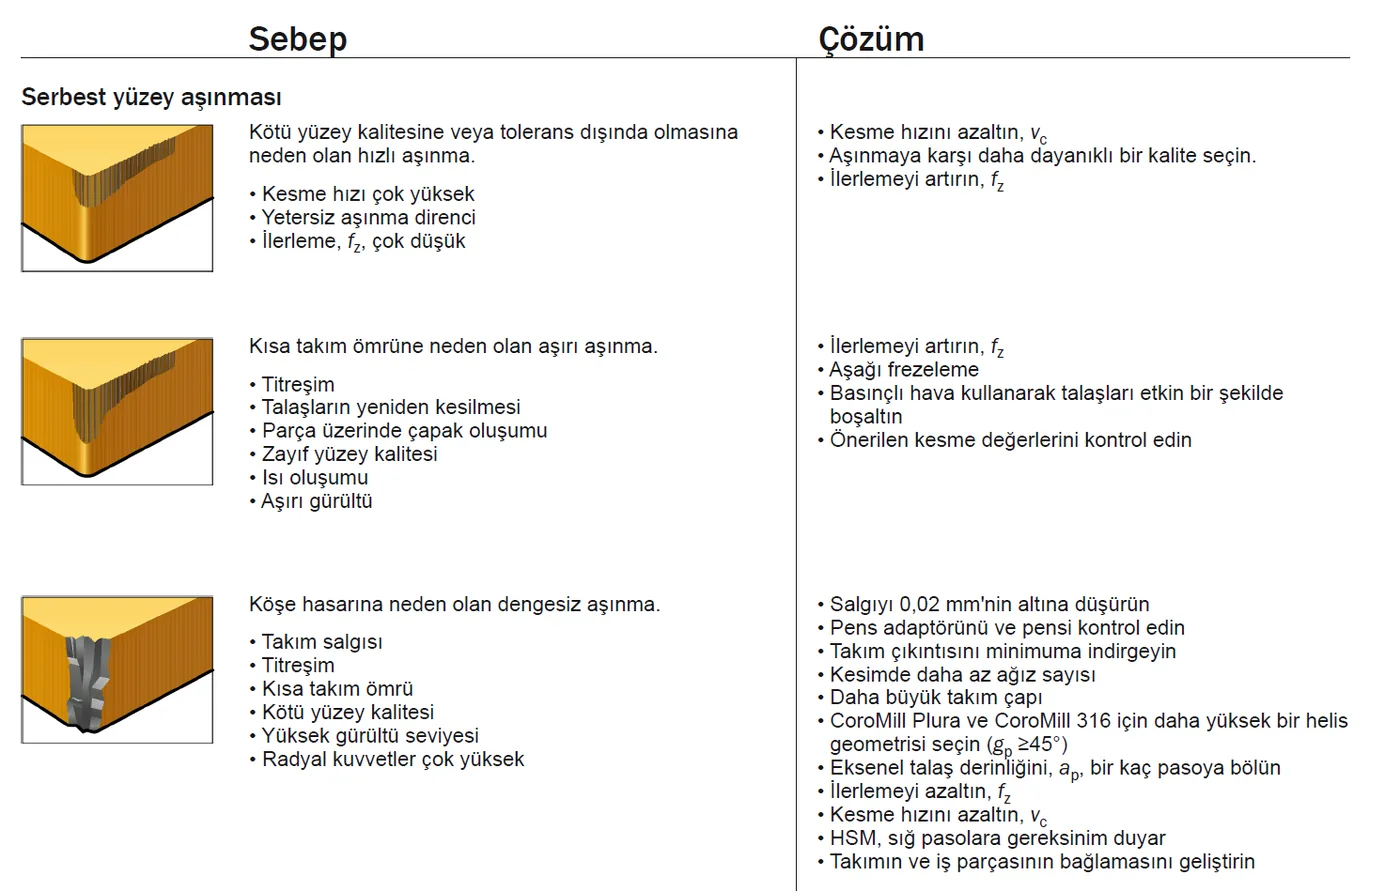
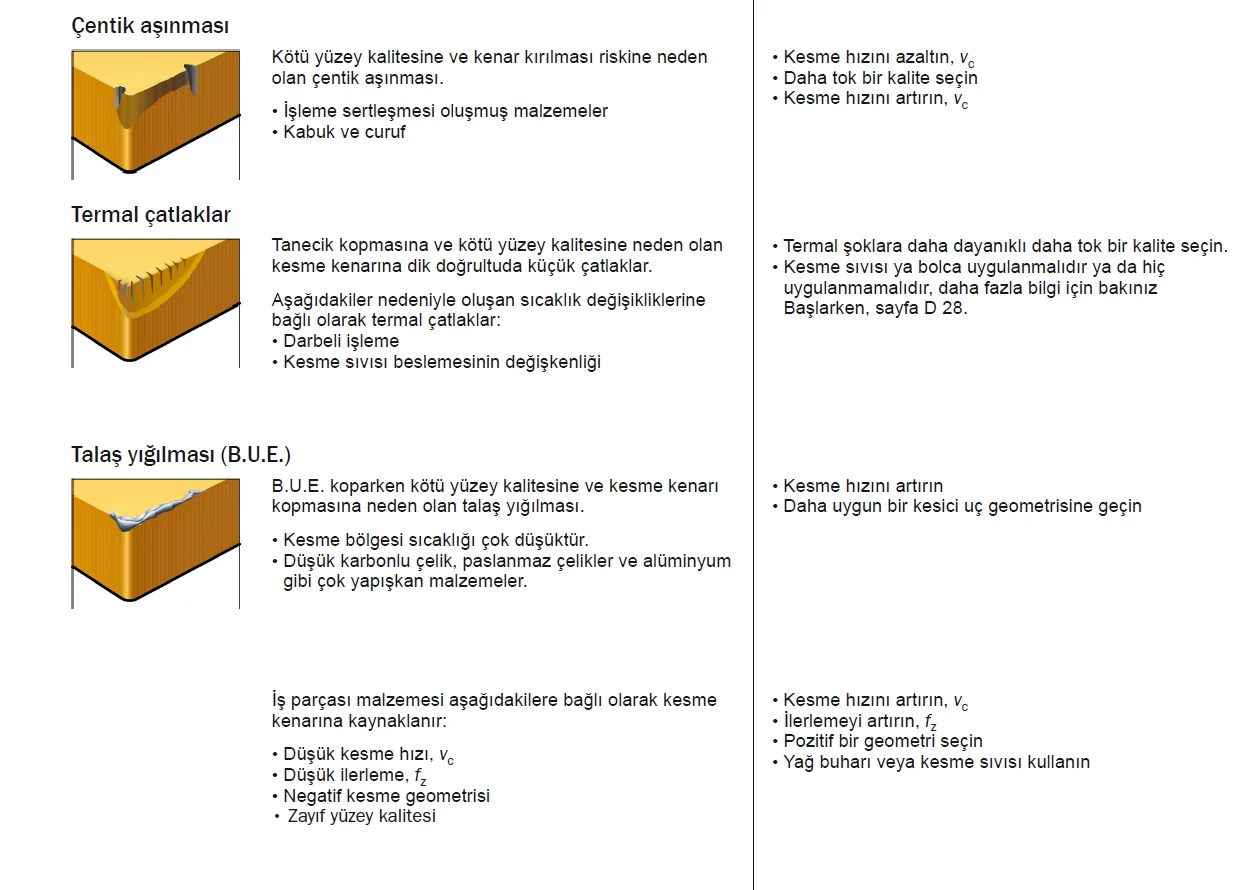
The table below collects problems specific to milling. For general wear types such as crater wear and plastic deformation, the wear table in the turning guide applies; only problems that behave differently in milling are listed here. Try each remedy one at a time, in small steps, and watch the result on the edge and on the part.
| Problem | Symptom | Likely Cause | Solution |
|---|---|---|---|
| Rapid flank wear | Poor surface, part out of tolerance, short tool life. | vc too high; fz too low (the edge rubs instead of cutting); vibration; chip recutting; insufficient wear resistance. | Reduce vc; increase fz; climb milling; blow chips away with compressed air; a more wear-resistant grade. |
| Uneven wear (one tooth wears much more) | Corner damage, high noise, poor surface. | Tool run-out; vibration; too many teeth in the cut at once. | Bring run-out below 0.02 mm; check collet and holder; shorten the overhang; fewer teeth in the cut or a larger diameter; high-helix (≥ 45°) end mills; split ap into several passes. |
| Thermal cracks | Small cracks perpendicular to the edge, then chipping. | Temperature swings in interrupted cutting; irregular coolant supply. | A tougher grade resistant to thermal shock; coolant either flood or none (see 6.1). |
| Built-up edge (BUE) | Smeared surface; the detaching BUE chips the edge. | Low vc and fz; negative geometry; sticky material (low-carbon steel, stainless, aluminum). | Increase vc and fz; positive, sharp geometry; oil mist or coolant. |
| Chipping / edge breakage | Micro-chipping of the edge, rapid surface deterioration. | Grade too brittle; weak geometry; impact at cut entry; BUE breaking off; chips directed at the edge. | Tougher grade and stronger edge; reduce the feed at entry or roll in; improve stability; if BUE is present, increase vc. |
| Vibration: weak fixturing | Wavy surface, noise, dimensions drifting. | The part is not supported in the direction of the cutting force. | Determine the force direction and add support; reduce ap; coarse, differential-pitch cutter; light-cutting geometry, small corner radius; avoid machining where the part is poorly supported. |
| Vibration: axially weak part | Thin floor or wall vibrates. | Axial cutting force deflects the part. | Positive 90° entering-angle cutter (small axial force); reduce ap, corner radius and parallel land. |
| Vibration: long tool overhang | Chatter in deep features. | Tool deflection; overhang exceeds 4 × length-to-diameter. | Minimize the overhang; largest possible holder diameter; differential pitch; balance the forces with a 45° entering angle or round inserts; increase fz; reduce ap; conventional milling in finishing; fewer flutes or higher helix on end mills; damped holders for very long overhangs. |
| Vibration: weak spindle + 90° cutter | Chatter in side milling on small machines. | Radial force deflects the spindle. | Smallest possible cutter diameter; positive, light-cutting insert; try conventional milling; check that spindle run-out is acceptable for the machine. |
| Vibration: irregular table feed | Sudden grabbing in climb milling. | Backlash in the feed screw. | Try conventional milling; have the feed-screw backlash adjusted. |
| Vibration: cutting data and corners | Chatter at a certain rpm; noise in corners. | Cutting data hits a resonance; arc of engagement grows in the corner. | Reduce vc, increase fz, change ap; program large corner radii at reduced feed (see 4.3, 7.7). |
| Chip jamming | Insert corner damage, edge breakage; in full slotting and deep pockets, especially in titanium and on vertical machines. | Chips cannot leave the slot and are recut. | Well-directed flood coolant or compressed air (preferably through the tool); reduce fz; split deep cuts into passes; try conventional milling in deep slots; 2–3 flute or high-helix end mills; change the toolpath strategy (trochoidal, see 7.6). |
| Poor surface finish: feed marks | Distinct, regular tooth marks. | Feed per revolution larger than the parallel land; inserts at different heights; spindle run-out. | Reduce the feed per revolution to at most 70% of the parallel land width; check insert heights with a dial indicator; check spindle run-out and cutter seating faces. |
| Poor surface finish: back cutting | Cross-hatched “lattice” pattern. | The trailing teeth cut the surface a second time. | Check the spindle tilt (about 0.10 mm per 1000 mm); axial run-out in finishing must not exceed 7 µm; smaller cutter diameter; make sure the cutter does not wobble. |
| Poor surface finish: exit marks and burrs | Edge frittering, burrs. | Thick chip at exit; BUE; worn edge. | Reduce fz; close-pitch cutter; position the cutter so the chip is thin at exit; 45° entering angle and light geometry; sharp edge; if BUE is present, increase vc and switch off the coolant. |
| Burr formation (HRSA, stainless) | Burrs on the part edge. | Material behaviour; notch wear. | Large insert radius (small effective entering angle); keep ap below the radius: round inserts ap ≤ 0.25 × iC, radius inserts ap ≤ 0.5 × rε. |
| Insufficient machine power | Spindle load at the limit, rpm dropping. | Metal removal rate, average chip thickness, geometry and vc together set the power; at low rpm motor power also falls. | Coarse-pitch cutter; a positive cutter needs less power than a negative one; reduce vc first, then table feed; smaller cutter with more passes; reduce ap; respect the machine’s power–rpm curve. |


Continue with Mentor CNC
This guide summarizes Mentor CNC’s knowledge of milling cutting-tool selection, entering angle and machining optimization. For the other machining guides in the series, explore the Cutting Tools category and our CNC calculators. Share your questions in the comments.
Try it yourself: With the CNC Milling CAM Simulator and G Code Generator you can apply the machining methods in this guide: pick a tool family, diameter and flute count, get the spindle speed and feed automatically, watch the toolpath in 3D and download the G code.